Train Robots for
the Real World.

Maati Labs turns real environments into physics grounded simulation so robots can train, test, and fail safely before deployment.
Grants & Awards
Scroll
Reality Simulation Edge Cases
The Real World Is
Messy.
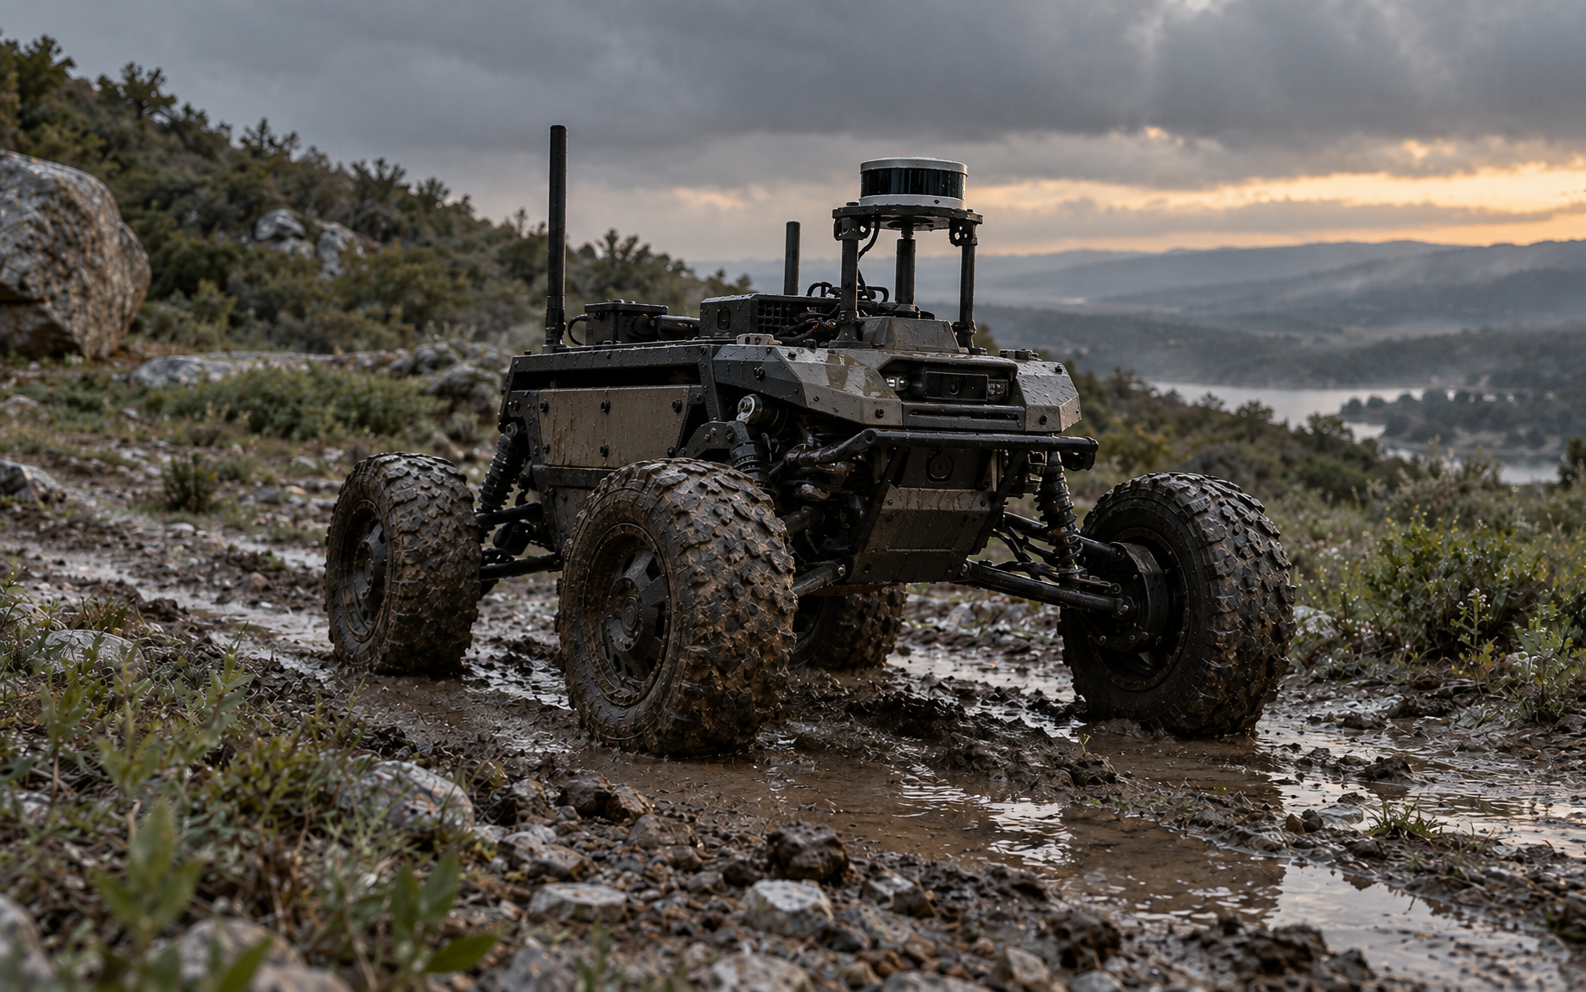
Robots leave the lab and meet loose terrain, changing surfaces, occlusions, impacts, slip, and conditions their training data did not cover.
Maati Labs Reconstructs
A World They Can Train In.
Maati Labs converts real environments into physics grounded digital twins that preserve the geometry, contact, terrain, and physical interactions robots need to learn from.
Test the Failures
Before Deployment.
Replay rare failures, vary physical conditions, and generate hard scenarios in simulation before a robot has to survive them in the real world.
01 / 03
Loading simulation
Maati / Edge Case Library
01 — 04
Real world robot run
REAL WORLD OBSERVATION
REAL WORLD OBSERVATION RUN_0427
Observed Environment
Robot motion / terrain / contact / physical conditions
Observe The Real World
Maati reconstructs geometry, terrain, contact, and physical state from real world observations.
Observed Inputs
Camera LiDAR IMU Wheel speed Terrain sensors
Reconstructed State
Geometry Terrain Friction Contact Traction Traversability
Current Model State
Surface friction 0.62
Terrain slope 6.2°
Wheel slip 8.7%
Ground moisture 31.4%
Confidence 94%
Robot velocity 1.3 m/s
Physics Constraints
Observed robot motion and sensor measurements constrain the reconstructed world.
State constrained by observation
Physical World Model
Reconstructed
Environment
geometry · terrain · contact · physical state
Wet terrain simulation
SIMULATION / WET TERRAIN
SIMULATION VAR_001
Wet Terrain
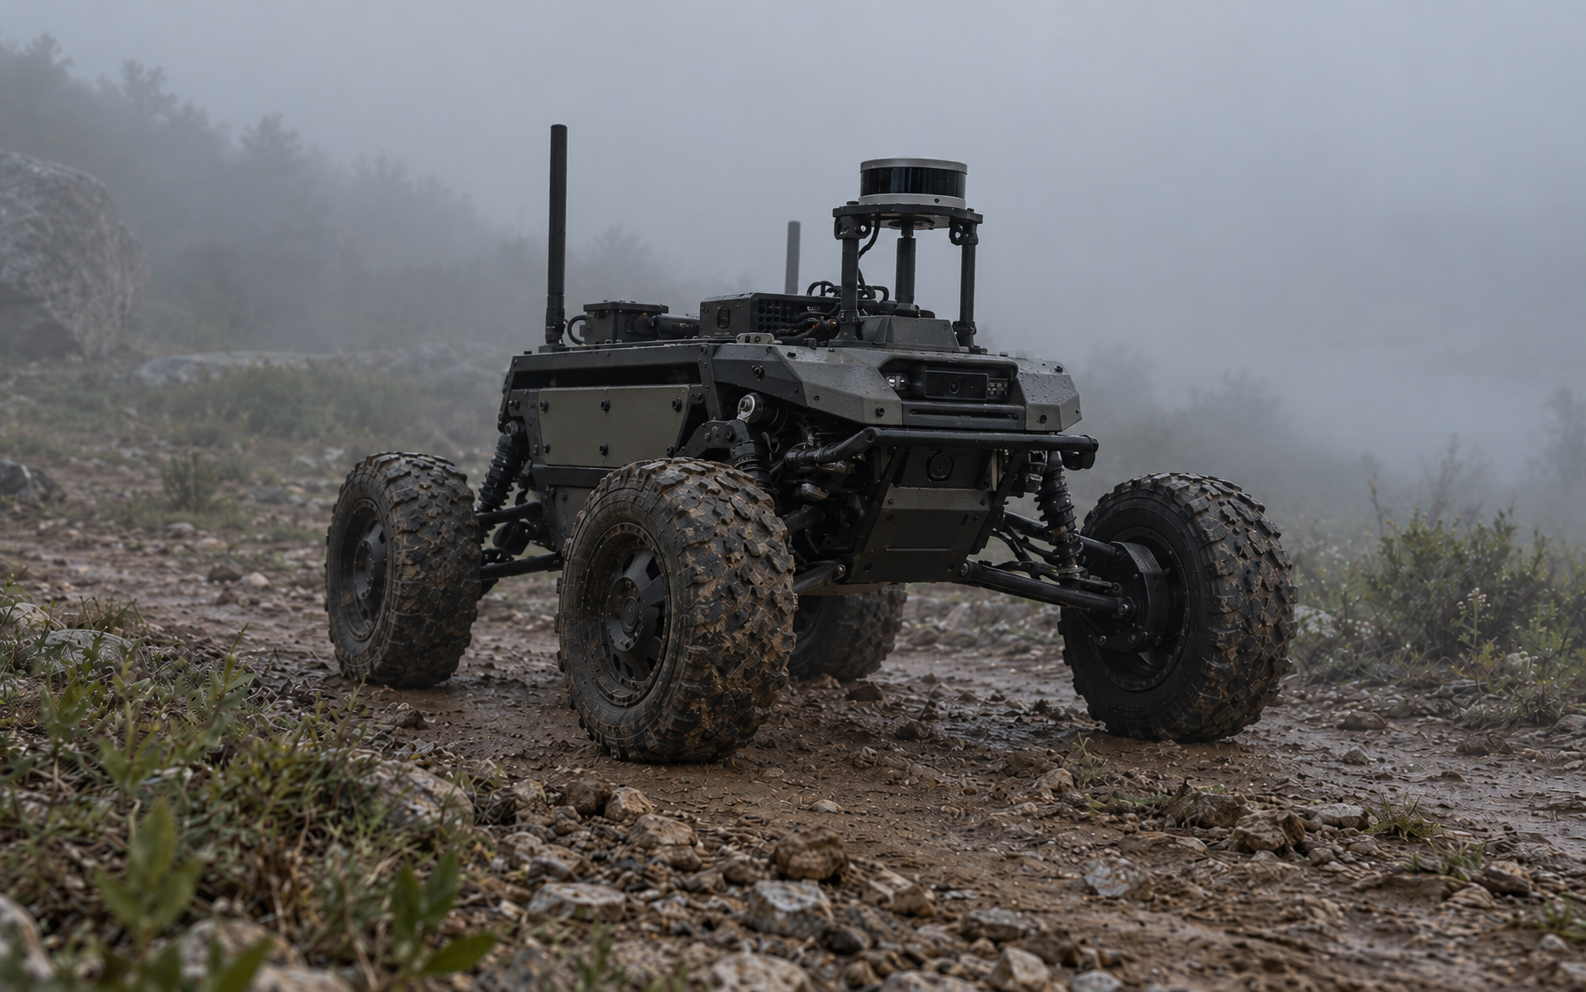
low friction terrain
01
SIM STATE
Moisture 47%
Friction 0.31
Wheel slip 22%
Low visibility simulation
SIMULATION / LOW VISIBILITY
SIMULATION VAR_002
Low Visibility
reduced perception range
02
SIM STATE
Visibility 18 m
LiDAR return 71%
Contrast 42%
Dynamic obstacle simulation
SIMULATION / DYNAMIC OBSTACLE
SIMULATION VAR_003
Dynamic Obstacle
moving object crossing
03
SIM STATE
Range 4.2 m
Obj speed 1.8 m/s
TTC 2.3 s
Loose debris simulation
SIMULATION / LOOSE DEBRIS
SIMULATION VAR_004
Loose Debris
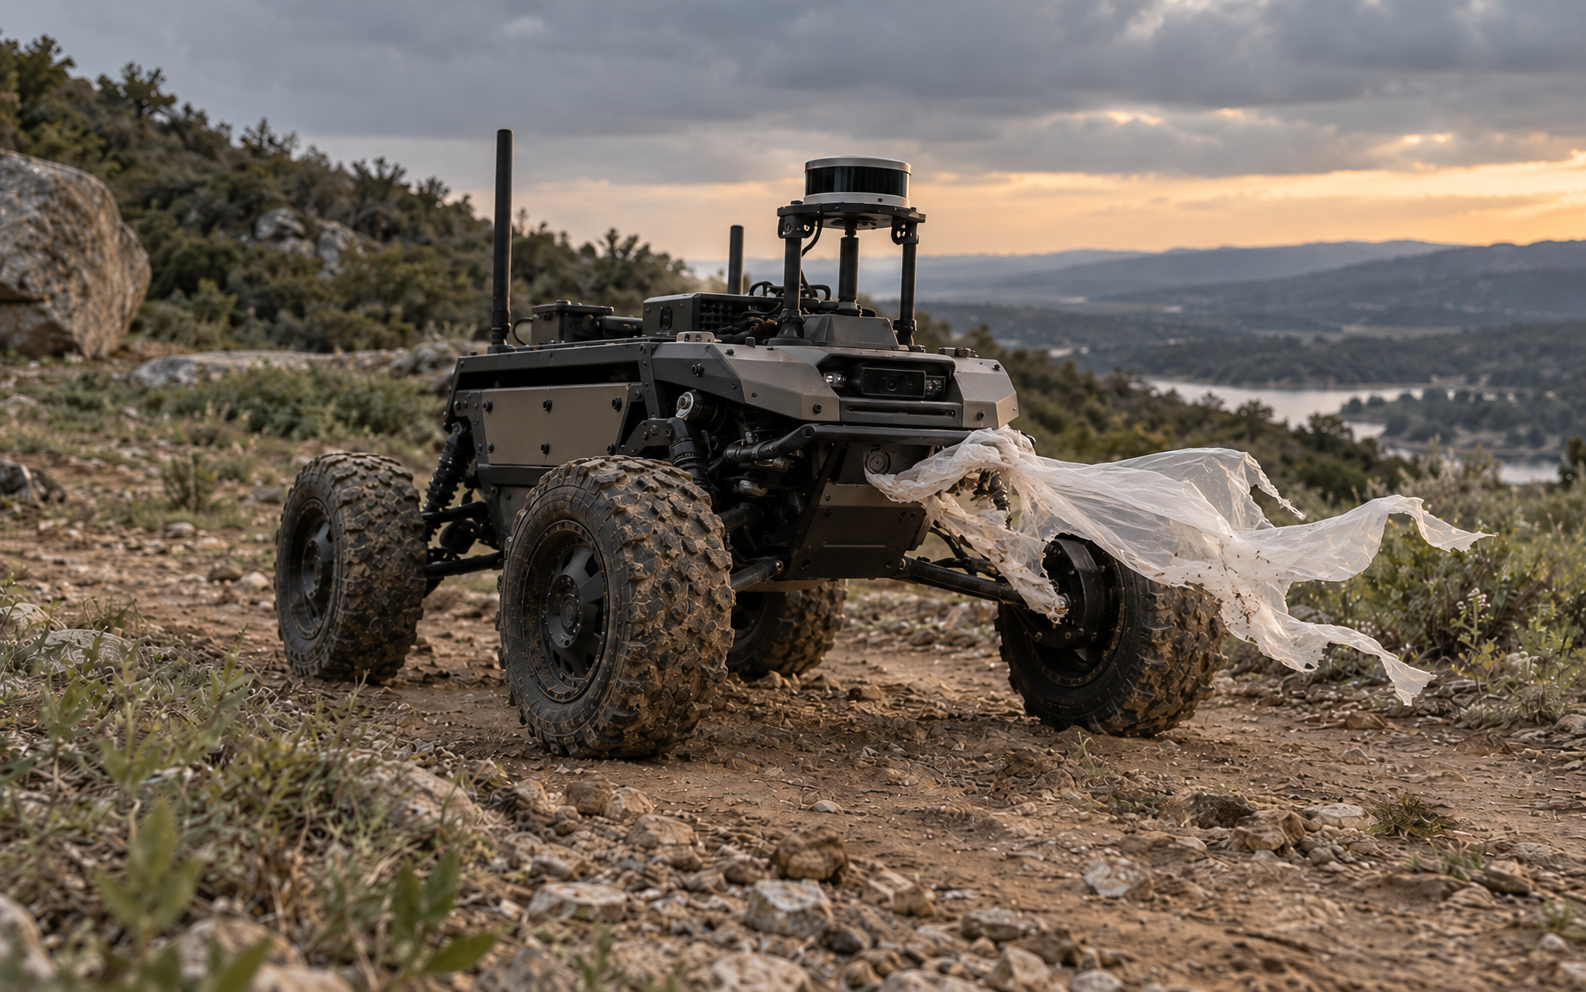
wheel and sensor contact
04
SIM STATE
Contact 84 N
Wheel load +14%
Motor current +19%
Traversal obstacle simulation
SIMULATION / TRAVERSAL OBSTACLE
SIMULATION VAR_005
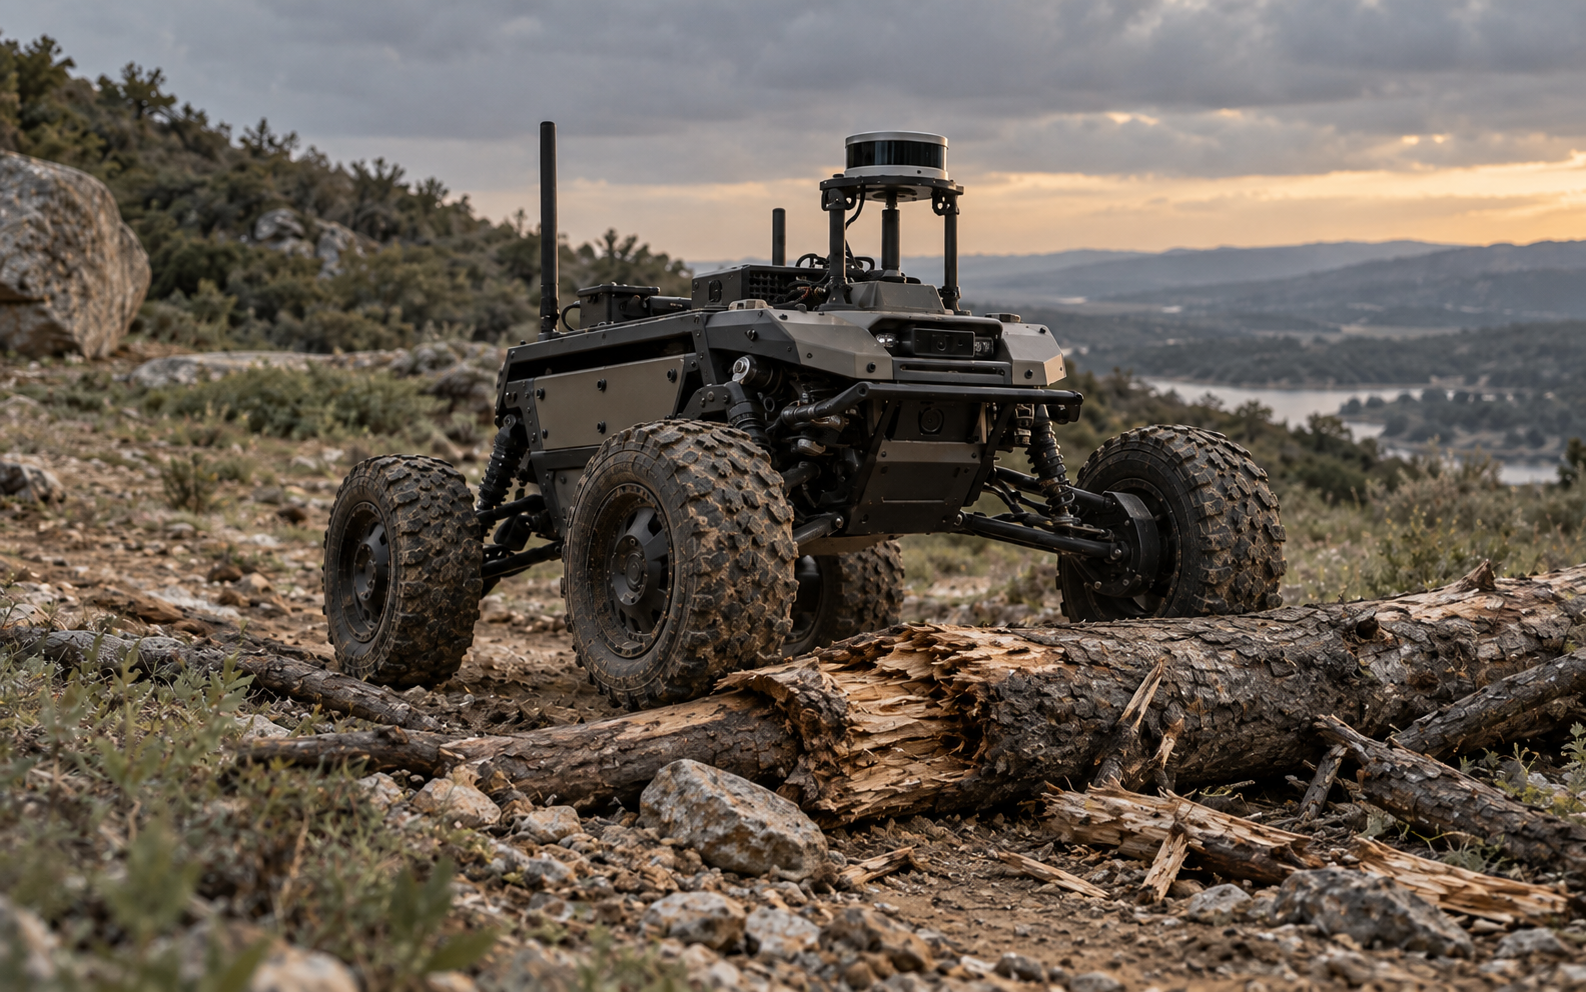
Traversal Obstacle
geometry and clearance
05
SIM STATE
Height 21 cm
Approach 17°
Clearance 8 cm
Traction loss simulation
SIMULATION / TRACTION LOSS
SIMULATION VAR_006
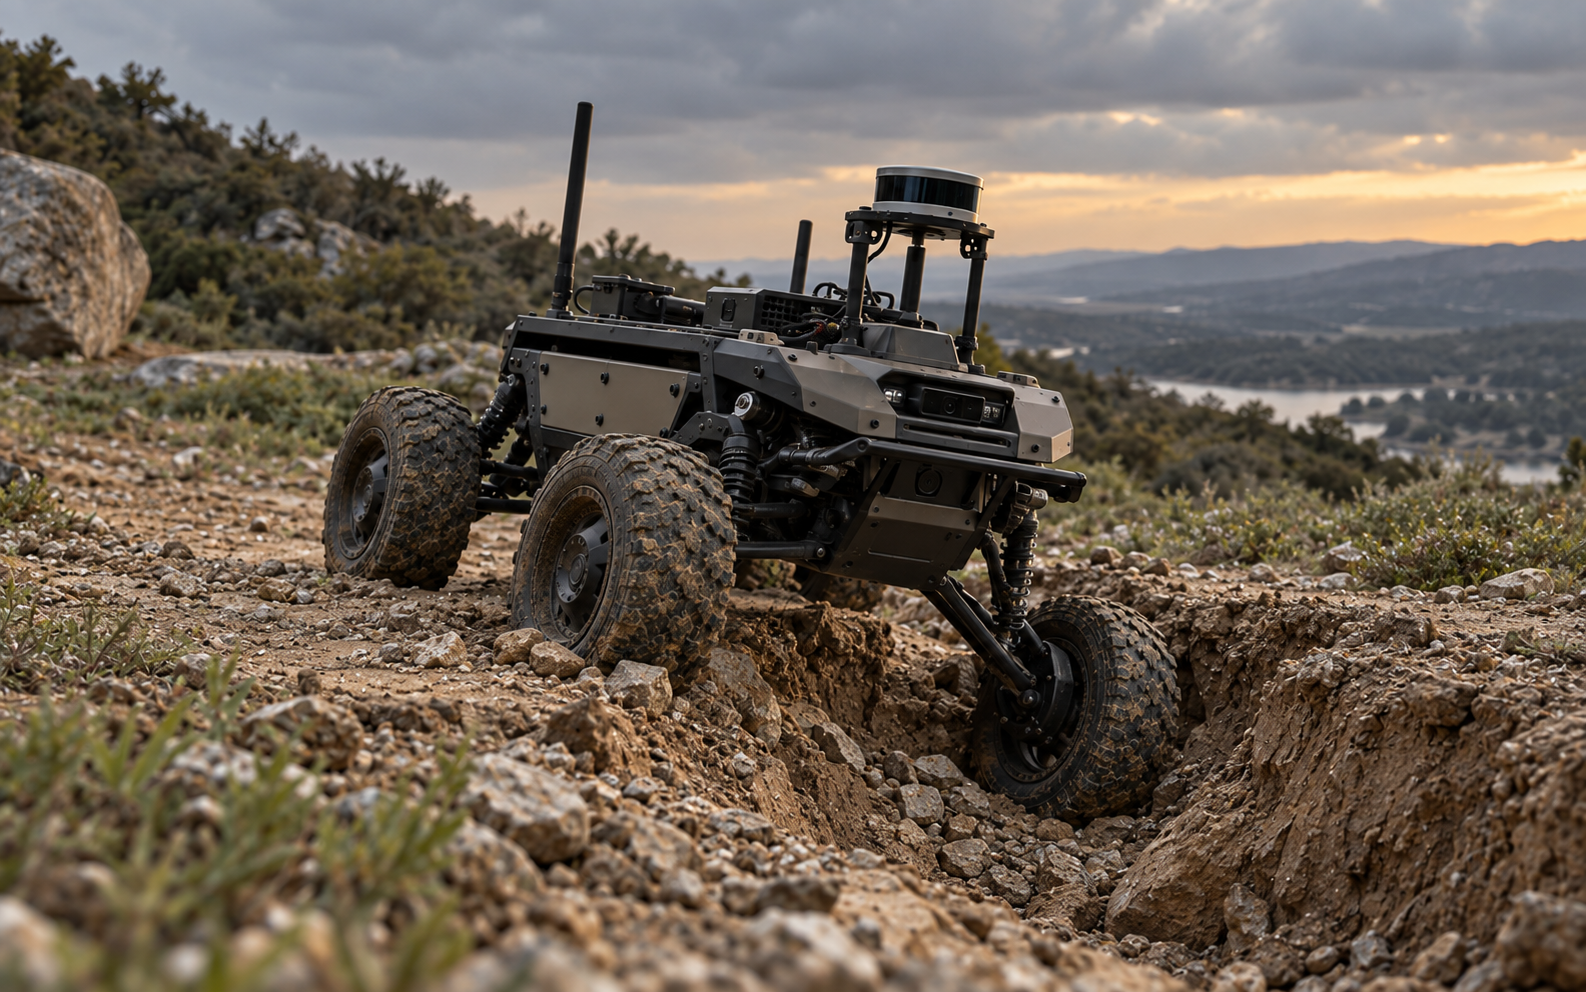
Traction Loss
unstable wheel ground contact
06
SIM STATE
Wheel slip 34%
Friction 0.27
Yaw rate 11°/s
PHASE / CAPTURE
Get In Touch

Let's get
in touch.

Talk to us about robot simulation, real world deployment data, research partnerships, or building new edge case environments with Maati Labs. We respond within 24 hours.

✓

Message sent. We will be in touch within 24 hours.